About Danon Robotica
Danon Robotica is an AI-powered platform that helps makers, engineers, students, and hobbyists design and build custom robotics kits from the ground up. Whether you are prototyping a wheeled rover, a robotic arm, a legged walker, or an autonomous drone, Danon Robotica turns your selection of integrated circuits into a complete, build-ready robot kit — complete with assembly instructions, wiring guides, and starter code.
The platform is built for anyone passionate about robotics. Students and educators use it to accelerate STEM learning without getting bogged down in parts research. Makers and hobbyists use it to go from idea to build in minutes instead of weeks. Professional engineers use it to rapidly prototype concepts and generate categorized Bills of Materials that are ready to source. No matter your experience level, Danon Robotica removes the friction between choosing your components and having a full robot design in hand.
At its core, the platform features a curated catalog of microcontrollers, sensors, motor drivers, communication modules, and power management ICs. Once you select the chips that power your idea, an AI design engine analyzes your choices and recommends every supporting component you will need — resistors, capacitors, connectors, motors, and more. It then generates a full robot specification including technical details, step-by-step assembly instructions, a wiring guide, and working starter code so you can hit the ground running.
Danon Robotica is built by a small team of robotics enthusiasts and software engineers who believe that building robots should be accessible to everyone. Our mission is to lower the barrier to entry for robotics and empower the next generation of builders, inventors, and problem-solvers. We are constantly expanding our component catalog, improving our AI design engine, and adding new features based on feedback from our community of makers.
Smart IC Catalog
Curated microcontrollers, sensors, drivers, and modules.
AI Design Engine
Auto-suggests components and generates full robot specs.
Printable BOM
Categorized, print-ready parts list for every build.
What a real design looks like
This is an actual example of what Danon Robotica generates from one prompt — the concept image, specifications, a wiring excerpt, starter code, and a sourced Bill of Materials. Nothing here is mockup text; it's representative of real output.
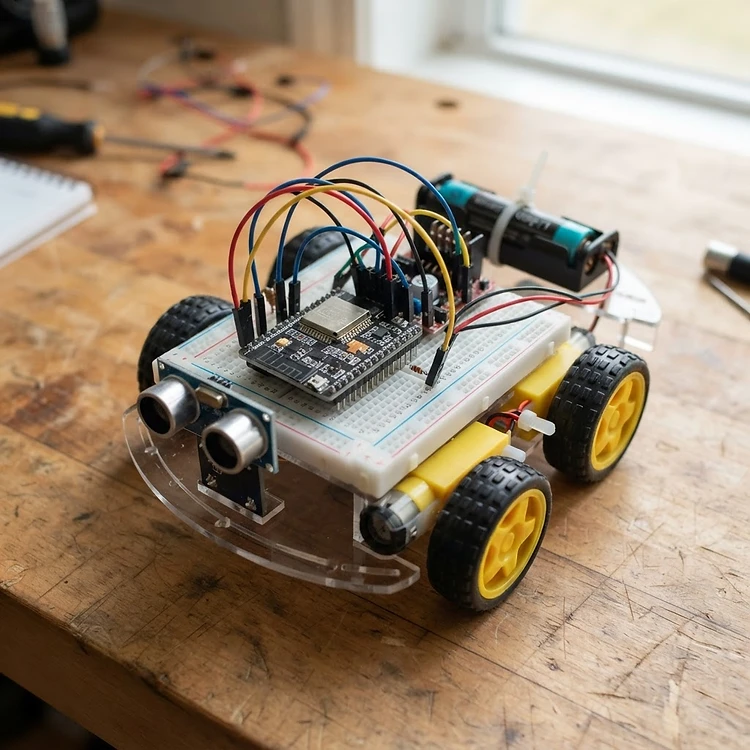
Line-Following Rover
A beginner-friendly two-wheeled robot that follows a black line, avoids obstacles, and can be steered over Bluetooth — generated from a single sentence.
dimensions
15 × 12 × 6 cm
weight
~280 g
power source
2× 18650 Li-ion (7.4 V)
mobility
2-wheel drive + caster
Wiring guide (excerpt)
ESP32  →  L298N motor driver
  GPIO 25  →  IN1
  GPIO 26  →  IN2
  GPIO 27  →  IN3
  GPIO 14  →  IN4
  GPIO 12  →  ENA (PWM)

ESP32  →  HC-SR04 ultrasonic
  GPIO 5   →  TRIG
  GPIO 18  →  ECHO

ESP32  →  IR line sensor (×3)
  GPIO 34  →  LEFT   (ADC)
  GPIO 35  →  CENTER (ADC)
  GPIO 32  →  RIGHT  (ADC)

POWER
  7.4 V battery  →  L298N 12V in + ESP32 VIN
  GND common  (battery · L298N · ESP32)
Starter code (excerpt)
// Line-Following Rover — starter sketch (ESP32)
#define IN1 25, IN2 26, IN3 27, IN4 14, ENA 12
#define IR_L 34, IR_C 35, IR_R 32

void setup() {
  pinMode(IN1, OUTPUT); pinMode(IN2, OUTPUT);
  pinMode(IN3, OUTPUT); pinMode(IN4, OUTPUT);
  ledcAttach(ENA, 1000, 8);          // PWM channel
  Serial.begin(115200);
}

void forward(int s) {
  ledcWrite(ENA, s);
  digitalWrite(IN1, HIGH); digitalWrite(IN2, LOW);
  digitalWrite(IN3, HIGH); digitalWrite(IN4, LOW);
}
void stop() { digitalWrite(IN1, LOW); digitalWrite(IN2, LOW);
              digitalWrite(IN3, LOW); digitalWrite(IN4, LOW); }

void loop() {
  int l = analogRead(IR_L), c = analogRead(IR_C), r = analogRead(IR_R);
  if (c > 2000)      forward(180);          // on the line
  else if (l > 2000) forward(160), turnLeft();   // drift left → correct
  else if (r > 2000) forward(160), turnRight();  // drift right → correct
  else               stop();               // lost the line
}
Sourced BOM (excerpt)
| Part | MPN | Qty | Unit |
|---|---|---|---|
| ESP32 DevKit | ESP32-WROOM-32E | 1 | $3.25 |
| L298N motor driver | L298N | 1 | $7.04 |
| HC-SR04 ultrasonic | HC-SR04 | 1 | $1.95 |
| IR line sensor | TCRT5000 | 3 | $1.50 |
| TT gear motor + wheel | ROB-13302 | 2 | $2.95 |
| 18650 Li-ion + holder | 18650 | 2 | $4.50 |
| Est. kit cost | $31.64 | ||
Full designs include every supporting component (resistors, capacitors, chassis, fasteners), live availability, datasheet links, and per-part buy buttons.
Supported hardware
Designs are generated around real, commonly-available parts you can buy today from Digi-Key, Mouser, Amazon, Adafruit, and SparkFun. If a part isn't listed, the AI still reasons about it from its category — but these are the workhorses it knows best.
Microcontrollers
- ESP32 / ESP8266
- Arduino Uno (ATmega328P)
- Arduino Nano
- Raspberry Pi Pico (RP2040)
- STM32 Blue Pill
Motor & Stepper Drivers
- L298N
- TB6612FNG
- DRV8833
- A4988 (stepper)
- ULN2003 (28BYJ-48)
Sensors
- HC-SR04 ultrasonic
- MPU6050 IMU
- VL53L0X ToF
- IR line follower
- DHT22 temp/humidity
- PIR motion
Communication
- HC-05 Bluetooth
- nRF24L01
- ESP-NOW
- LoRa SX1278
- MFRC522 RFID
Power Management
- TP4056 Li-ion charger
- LM2596 buck converter
- MT3608 boost
- XL4015
- 7805 regulator
Display & Output
- SSD1306 OLED
- WS2812 / NeoPixel
- 16x2 LCD (I2C)
- TM1637 7-seg
- Buzzer
Actuators
- SG90 / MG90S servo
- N20 gear motor
- 28BYJ-48 stepper
- TT DC gear motor
Real builds from the community
Every entry below is a real robot design generated on Danon Robotica by a real builder — the concept image, specs, and overview are exactly what the AI produced.
No community builds published yet. Be the first — design a robot and it can appear here.
Engineering limitations & disclaimers
We'd rather be honest about what AI can and can't do than oversell it. Here's what to expect from every design Danon Robotica generates.
Verify before you power on
AI-generated wiring is a starting point, not a guarantee. Double-check pin assignments, voltage levels, and polarity — especially motor-driver power and battery connections — before applying power.
Code is a scaffold, not firmware
Starter code is meant to be read, understood, and tested. Run small movements first, watch current draw, and review anything used in safety-critical or unattended applications.
Not a substitute for professional review
For commercial, medical, or safety-critical use, have a qualified engineer review the design. Danon Robotica accelerates prototyping; it does not certify products.
Prices & availability are estimates
Sourced BOM prices and 3D-print costs are approximate and change over time. Always confirm the live price and stock on the distributor's page before ordering.
By using Danon Robotica you acknowledge that generated designs are provided as-is, for prototyping and educational use, without warranty. You are responsible for verifying safety and correctness before building.